RAYBOT
is an AI-powered autonomous water-quality monitoring rover inspired by the natural movement of aquatic animals. We developed it to address a simple but important problem:
monitoring water quality across a large water body is difficult, time-consuming, and often requires human intervention.
Traditional monitoring generally depends on collecting water samples at selected locations and testing them separately. This can miss changes occurring between sampling points. RAYBOT is designed to bring sensing, mobility, vision, and intelligence together in a single platform.
How RAYBOT worksRAYBOT uses biomimetic sine-wave propulsion instead of conventional propellers. Multiple servo-driven fin sections create a phase-shifted traveling wave, allowing the flexible fin to generate an undulatory swimming motion inspired by fish and rays.
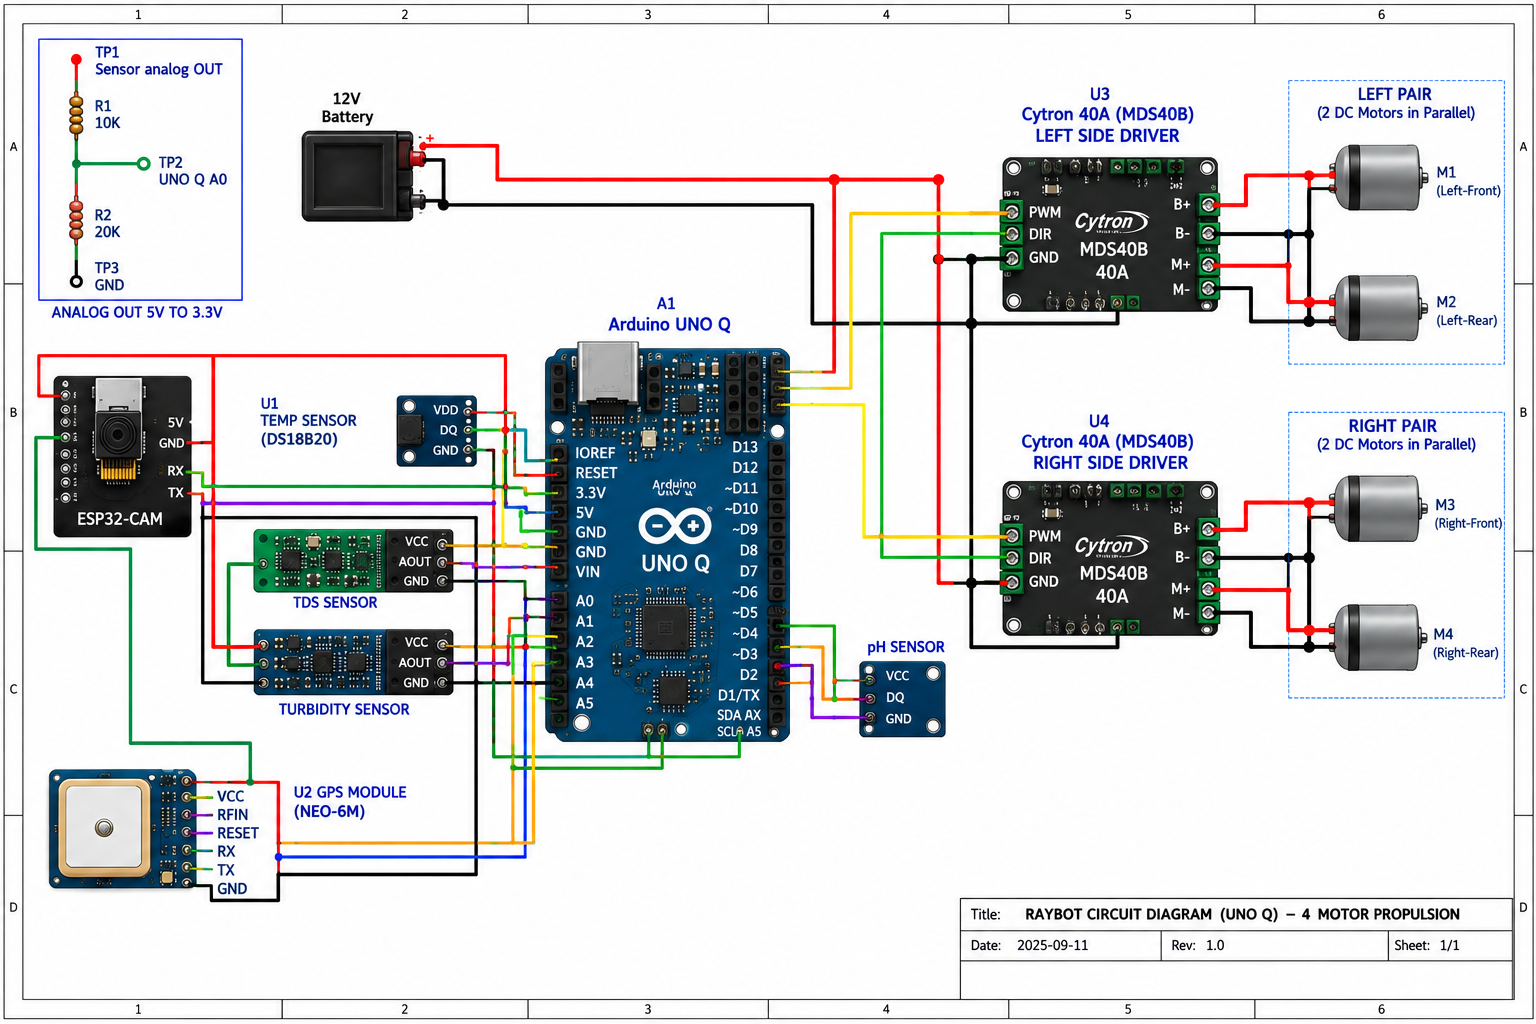
The rover carries multiple water-quality sensors to measure:
- pH – acidity/alkalinity
- TDS – total dissolved solids
- Turbidity – water clarity
- Temperature – water temperature
An ESP-CAM provides visual monitoring, while GPS enables location tracking. The Arduino UNO Q acts as the onboard processing platform, combining sensor information and supporting edge-AI processing for real-time analysis and decision-making.
The overall workflow is:
Sense → Process → Analyze → Locate → Monitor → Act
Our goal is to develop RAYBOT into a platform capable of continuously exploring water bodies, identifying changes in water conditions, and providing actionable information without requiring constant manual sampling.
What we are demonstratingOur current prototype demonstrates the core concept through:
6-servo sine-wave fin propulsion → water-quality sensing → onboard processing → camera-based monitoring → GPS tracking. version-1
The project combines biomimetic robotics, embedded systems, IoT, AI, and environmental monitoring to create a more intelligent and sustainable approach to aquatic exploration.




Comments