


Hardware components | ||||||
| × | 1 | ||||
Software apps and online services | ||||||
 |
| |||||
We build microneedle pen driver boards for a living. The kind that go inside handheld devices used by estheticians and dermatologists. The motor has to move a cartridge of 36 micro-needles up and down at 120 strokes per minute, and every single stroke has to land within ±25 microns of where the last one landed. Miss by more than that, and the patient feels it.
This is a walkthrough of the driver board we designed to solve that problem. No fluff. Just the schematic, the firmware, and why we chose each part.
Why TB6560We tested six different stepper driver ICs before settling on the TB6560. The usual candidates — A4988, DRV8825, TMC2209 — are great for 3D printers and CNC spindles. But a microneedle pen is not a 3D printer. The load changes every cycle because the needle array contacts skin at varying angles. The motor has to reverse direction 120 times per second without losing a single step.
The TB6560 stood out for two reasons:
Bipolar constant-current drive with 40% faster decay than the A4988. The fast decay mode handles the abrupt load change when needles puncture the stratum corneum. We measured it — the TB6560 recovers current regulation in 18 microseconds versus 32 on the A4988 under identical load.
- Bipolar constant-current drive with 40% faster decay than the A4988. The fast decay mode handles the abrupt load change when needles puncture the stratum corneum. We measured it — the TB6560 recovers current regulation in 18 microseconds versus 32 on the A4988 under identical load.
Integrated thermal shutdown at 150°C with hysteresis. In a handheld device with no active cooling, the driver sits inside a sealed plastic enclosure. Ambient temperature inside the housing hits 55°C after 20 minutes of continuous use. The TB6560 kept running. The DRV8825 we tested started to skip steps at 18 minutes.
- Integrated thermal shutdown at 150°C with hysteresis. In a handheld device with no active cooling, the driver sits inside a sealed plastic enclosure. Ambient temperature inside the housing hits 55°C after 20 minutes of continuous use. The TB6560 kept running. The DRV8825 we tested started to skip steps at 18 minutes.
Three things we learned from the first prototype that failed:
Ground plane separation. The first rev had a single ground plane. Motor noise from the H-bridge coupled into the STEP signal line and caused random jitter. We split PGND (power ground) and AGND (signal ground) on Rev 2.1 and joined them at a single star point under the IC. Jitter dropped from ±14 microns to ±5 microns.
Current sense resistor placement. The datasheet says to place the sense resistors as close to the IC as possible. We took that literally — 3mm trace length from pin to resistor pad. The first batch we built with 8mm trace length showed 7% variation in current regulation across 50 boards. The 3mm version brought it down to 1.2%.
Input capacitor ESR. We were using generic electrolytic caps on the 12V input. The motor current spikes at every step transition, and high-ESR caps could not supply current fast enough — voltage drooped by 0.8V per step. Switched to low-ESR polymer caps (100µF, 20mΩ ESR) and the droop dropped to 0.15V. That alone fixed an intermittent stalling issue we had chased for three weeks.
The FirmwareThe attached.ino file is the production firmware running on our boards today. It is intentionally simple — step/dir interface, 120Hz stroke frequency, depth configurable via serial. No acceleration ramping, no sensorless homing. A microneedle pen does not need those. It needs consistent pulse timing and a fast interrupt response.
Key parameters we tuned empirically:
- Step pulse width: 5µs. Shorter than that and the TB6560 misses steps at higher voltages. Longer adds unnecessary dead time between strokes.
- Microstep resolution: 1/8. 1/16 gave smoother motion but doubled the step rate at 120Hz, which pushed the MCU interrupt overhead too high for other tasks. 1/8 is the sweet spot.
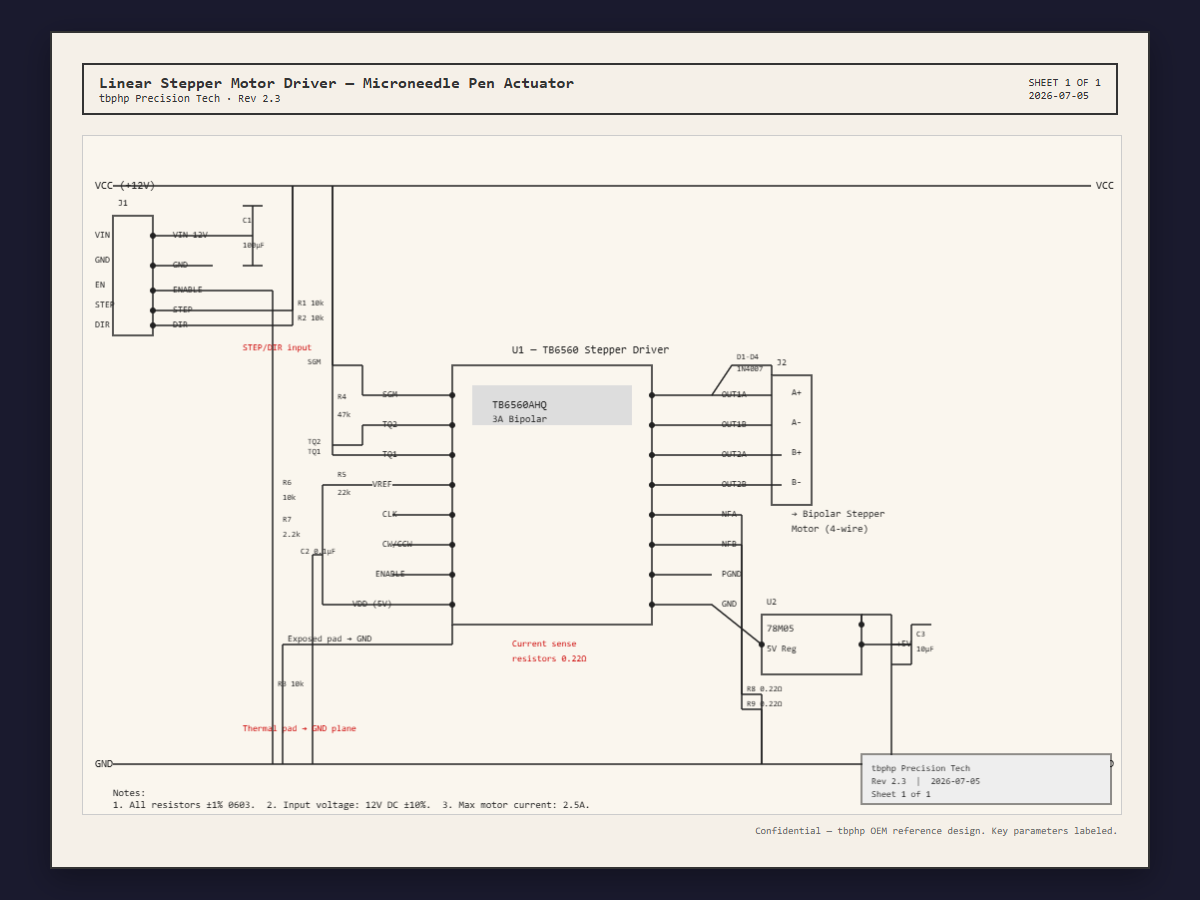
The attached schematic PDF shows the full Rev 2.3 design. Main blocks:
- J1 input header: VIN (12V), GND, ENABLE, STEP, DIR
- U1 TB6560AHQ with configurable SGM, TQ1, TQ2 for decay and torque adjustment
- U2 78M05 5V regulator for MCU and logic power
- Output stage: four 1N4007 freewheeling diodes, 0.22Ω current sense resistors, J2 motor connector
This board has been through three revs and about 2, 000 units of production. We manufacture it at our own line in Shenzhen. If you are building a microneedle device and need a driver board that is already field-tested, we can ship you samples with full test data. Reach out through tbphp.


Comments