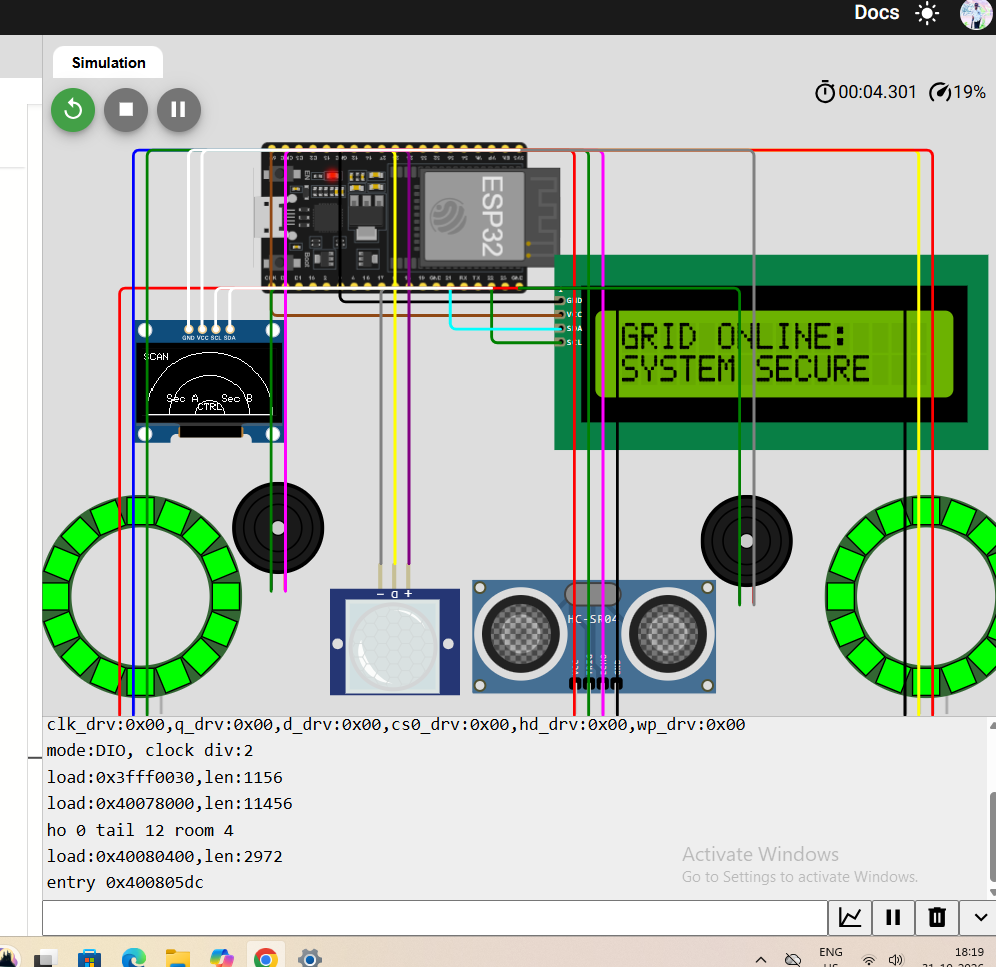
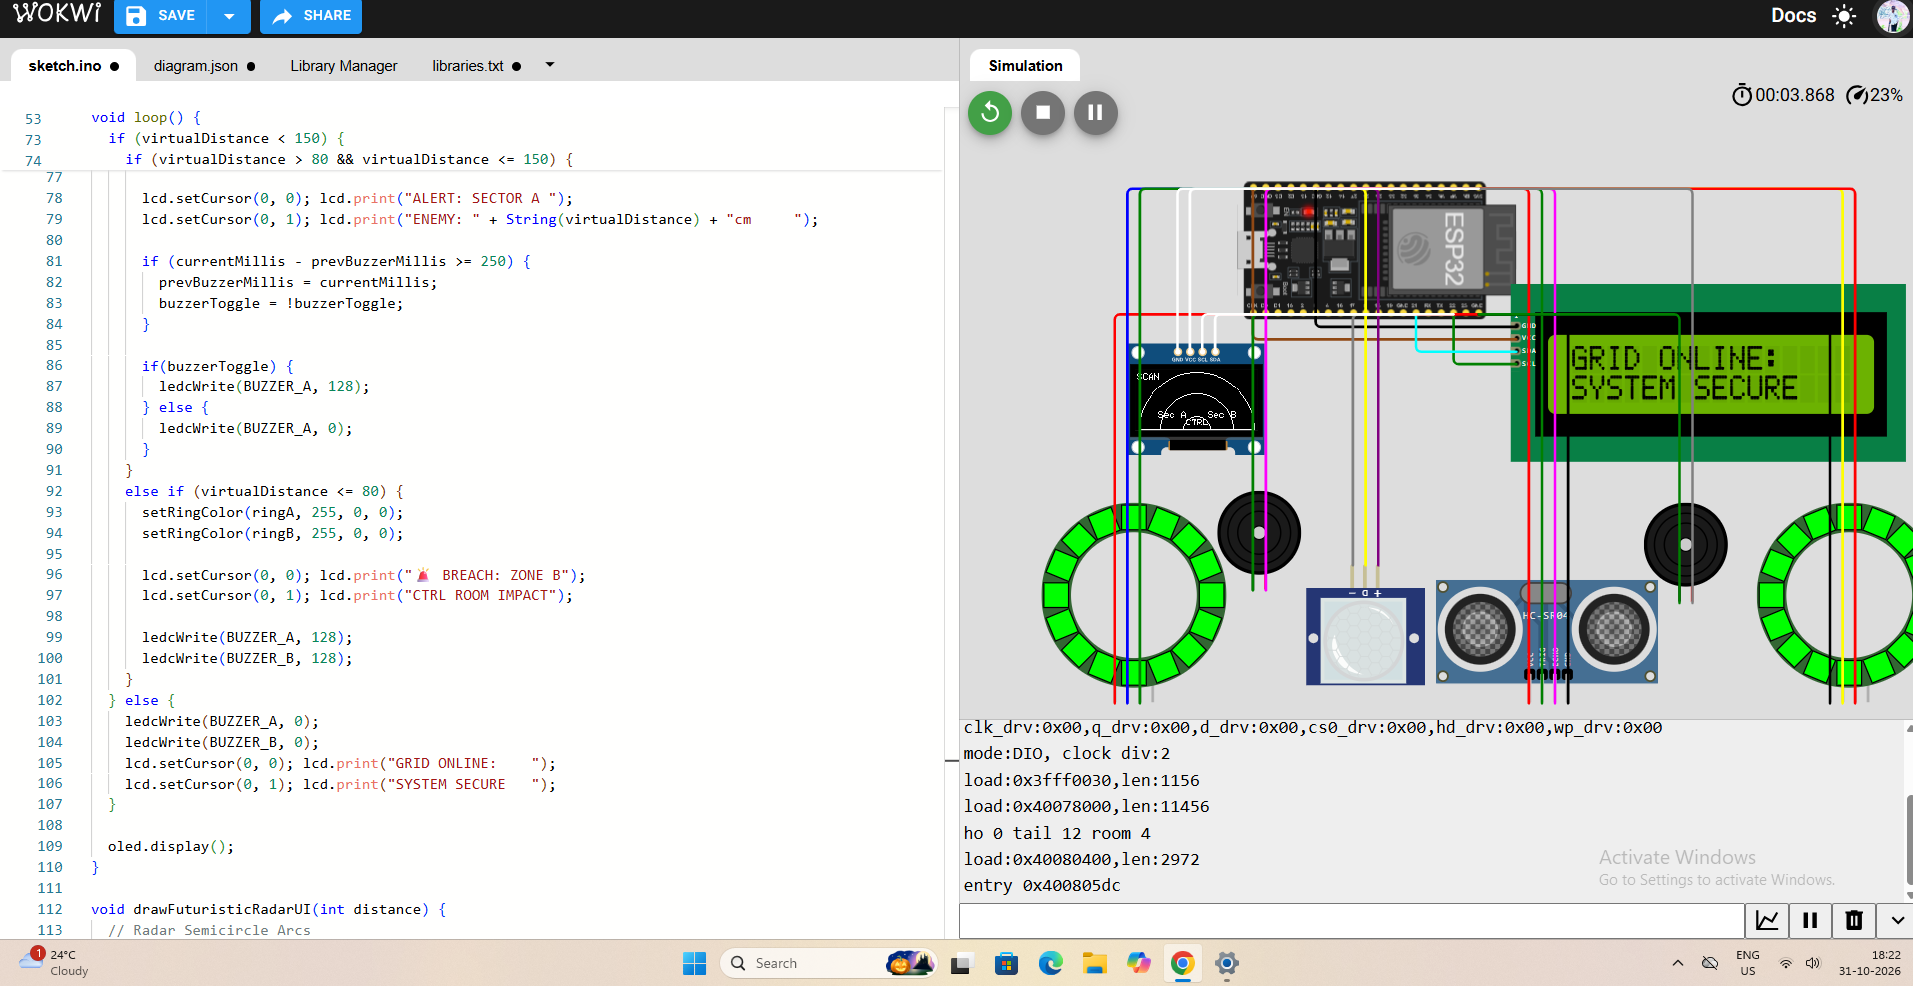
// Autonomous Smart Military Defense System Prototype
// Built on Wokwi Simulator - Designed by Tushar Gupta

#include <Wire.h>
#include <Adafruit_GFX.h>
#include <Adafruit_SSD1306.h>

#define SCREEN_WIDTH 128
#define SCREEN_HEIGHT 64
Adafruit_SSD1306 displayNormal(SCREEN_WIDTH, SCREEN_HEIGHT, &Wire, -1);
Adafruit_SSD1306 displayRadar(SCREEN_WIDTH, SCREEN_HEIGHT, &Wire, -1);

const int PIR_PIN = 12;
const int TRIG_PIN = 14;
const int ECHO_PIN = 27;
const int BUZZER_PIN = 26;

void setup() {
  Serial.begin(115200);
  pinMode(PIR_PIN, INPUT);
  pinMode(TRIG_PIN, OUTPUT);
  pinMode(ECHO_PIN, INPUT);
  pinMode(BUZZER_PIN, OUTPUT);

  if(!displayNormal.begin(SSD1306_SWITCHCAPVCC, 0x3C)) Serial.println("Display 1 Error");
  if(!displayRadar.begin(SSD1306_SWITCHCAPVCC, 0x3D)) Serial.println("Display 2 Error");

  displayNormal.clearDisplay();
  displayNormal.setTextSize(1);
  displayNormal.setTextColor(WHITE);
  displayNormal.setCursor(0, 10);
  displayNormal.println("SYSTEM READY");
  displayNormal.display();
}

void loop() {
  long duration;
  int distance;
  int intruderDetected = digitalRead(PIR_PIN);

  digitalWrite(TRIG_PIN, LOW);
  delayMicroseconds(2);
  digitalWrite(TRIG_PIN, HIGH);
  delayMicroseconds(10);
  digitalWrite(TRIG_PIN, LOW);
  duration = pulseIn(ECHO_PIN, HIGH);
  distance = duration * 0.034 / 2;

  if (intruderDetected == HIGH) {
    handleAlert(distance);
  } else {
    resetSystem();
  }
  delay(200);
}

void handleAlert(int dist) {
  displayNormal.clearDisplay();
  displayRadar.clearDisplay();

  displayNormal.setCursor(0,0);
  displayNormal.setTextSize(2);
  displayNormal.println("!! ALERT !!");
  displayNormal.setTextSize(1);
  displayNormal.print("Distance: ");
  displayNormal.print(dist);
  displayNormal.println(" cm");
  displayNormal.display();

  displayRadar.drawCircle(64, 63, 50, WHITE);
  if (dist < 20) {
    analogWrite(BUZZER_PIN, 255);
  } else {
    analogWrite(BUZZER_PIN, 100);
  }
  displayRadar.display();
}

void resetSystem() {
  noTone(BUZZER_PIN);
  displayNormal.clearDisplay();
  displayNormal.setCursor(0,10);
  displayNormal.setTextSize(1);
  displayNormal.println("Border Status: SECURE");
  displayNormal.display();
}
Main_ESP32_Firmwar




Comments