edge lab LIVE! starts Tuesday in Munich. Grab a workshop seat and take home the board you build on. Code FRIEND-HACKSTER saves 20%. (0d 0h 16m 983s) Learn more!
Luc Paquin
Published © CC BY

Project #15: Environment – GPS and RTC – Mk48

Project #15: Environment – GPS and RTC – Mk48

BeginnerFull instructions provided1 hour14
Project #15: Environment – GPS and RTC – Mk48

Things used in this project

Hardware components

DFRobot FireBeetle 2 ESP32-E
×1
Fermion: 3.5” 480x320 TFT LCD Capacitive
×1
GDL Line 10 CM
×1
Gravity: GNSS GPS BeiDou Receiver Module
×1
Gravity: I2C SD2405 RTC Module
DFRobot Gravity: I2C SD2405 RTC Module
×1
Gravity: IO Shield for FireBeetle 2
×1
Terminal Block Terminal Block Board for FireBeetle 2 ESP32-E IoT
×1
Lithium Ion Battery - 1000mAh
×1
USB 3.0 to Type-C Cable
×1

Software apps and online services

Arduino IDE
Arduino IDE

Story

Read more

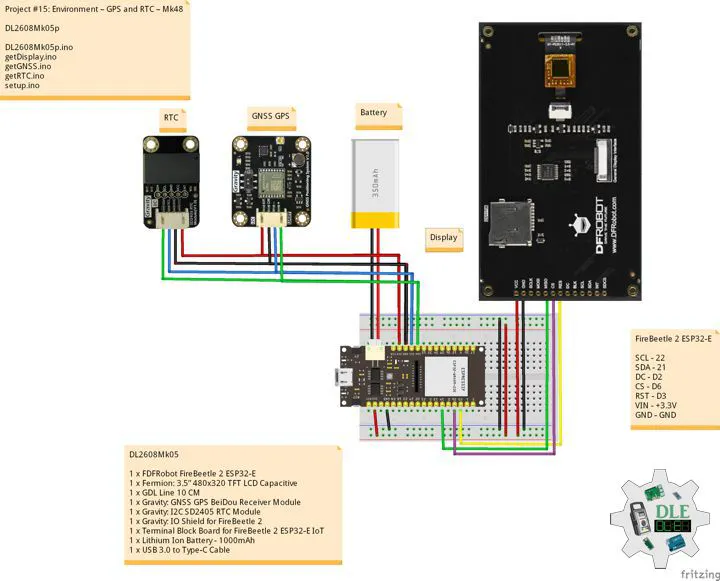
Schematics

Fritzing

Code

DL2608Mk05p.ino

Arduino
/****** Don Luc Electronics © ******
Software Version Information
Project #15: Environment – GPS and RTC – Mk48
15-48
DL2608Mk05p.ino
DL2608Mk05
1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480x320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Gravity: GNSS GPS BeiDou Receiver Module
1 x Gravity: I2C SD2405 RTC Module
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// DFRobot Display GDL API
#include <DFRobot_GDL.h>
// GNSS GPS
#include <DFRobot_GNSS.h>
// RTC (Real-Time Clock)
#include "GravityRtc.h"

// RTC Initialization
GravityRtc rtc;
// Date and Time
String dateRTC = "";
String timeRTC = "";

// GNSS GPS
// Use I2C for communication, but use the serial port for
// communication if the line of codes were masked
#define I2C_COMMUNICATION
// ESP32 user hardware uart
DFRobot_GNSS_I2C gnss(&Wire, GNSS_DEVICE_ADDR);
String sDate = "";
String sUTC = "";
String sLat = "";
String sLon = "";
String sAlt = "";

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 320x480
DFRobot_ILI9488_320x480_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
String sver = "15-48";

void loop() {
  
  // isGNSS
  isGNSS();

  // RTC (Real-Time Clock)
  isRTC();

  // isDisplay GPS RTC
  isDisplayGPSRTC();

  // Delay 1 Second
  delay( 1000 );

}

getDisplay.ino

Arduino
// DFRobot Display 320x480
// DFRobot Display 320x480 - UID
void isDisplayUID(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // Tilt Switch
  screen.setCursor(0, 60);
  screen.println("GPS and RTC");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );

}
// isDisplay GPS RTC
void isDisplayGPSRTC(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => white
  screen.fillScreen(0xffff);
  // Text Color => blue
  screen.setTextColor(0x001F);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // IP65 Capacitive Soil Moisture Sensor
  screen.setCursor(0, 30);
  screen.println("GPS and RTC");
  // Latitude
  screen.setCursor(0, 70);
  screen.println("Latitude: ");
  screen.setCursor(170, 70);
  screen.println( sLat );
  // Longitude
  screen.setCursor(0, 100);
  screen.print("Longitude: ");
  screen.setCursor(170, 100);
  screen.println( sLon );
  // GPS Date
  screen.setCursor(0, 130);
  screen.println("GPS Date: ");
  screen.setCursor(170, 130);
  screen.println( sDate );
  // GPS Time
  screen.setCursor(0, 160);
  screen.println("GPS Time: ");
  screen.setCursor(170, 160);
  screen.println( sUTC );
  // Altitude
  screen.setCursor(0, 190);
  screen.println("GPS Altitude: ");
  screen.setCursor(170, 190);
  screen.print( sAlt );
  screen.setCursor(290, 190);
  screen.println( "M" );
  // Date
  screen.setCursor(0, 220);
  screen.println("Date: ");
  screen.setCursor(170, 220);
  screen.println( dateRTC );
  // Time
  screen.setCursor(0, 250);
  screen.println("Time: ");
  screen.setCursor(170, 250);
  screen.println( timeRTC );
  
}

getGNSS.ino

Arduino
// GNSS
// isSetupGNSS
void isSetupGNSS(){
  
  // GNSS
  gnss.begin();
  
  // GNSS
  gnss.enablePower();      
/** Set the galaxy to be used
 *   eGPS              USE gps
 *   eBeiDou           USE beidou
 *   eGPS_BeiDou       USE gps + beidou
 *   eGLONASS          USE glonass
 *   eGPS_GLONASS      USE gps + glonass
 *   eBeiDou_GLONASS   USE beidou +glonass
 *   eGPS_BeiDou_GLONASS USE gps + beidou + glonass
 */
  gnss.setGnss(eGPS_BeiDou_GLONASS);
  // GNSS
  // gnss.setRgbOff();
  gnss.setRgbOn();
  
}
// isGNSS
void isGNSS(){

  // GNSS
  sTim_t utc = gnss.getUTC();
  sTim_t date = gnss.getDate();
  sLonLat_t lat = gnss.getLat();
  sLonLat_t lon = gnss.getLon();
  double high = gnss.getAlt();
  
  sDate = "";
  sUTC = "";
  sLat = "";
  sLon = "";
  sAlt = "";
  // Latitude
  sLat = lat.latitudeDegree;
  // Longitude
  sLon = lon.lonitudeDegree;
  // Date
  sDate = date.year;
  sDate = sDate + "/";
  sDate = sDate + date.month;
  sDate = sDate + "/";
  sDate = sDate + date.date;
  // UTC
  sUTC = utc.hour;
  sUTC = sUTC + ":";
  sUTC = sUTC + utc.hour;
  sUTC = sUTC + ":";
  sUTC = sUTC + utc.minute;
  // Altitude
  sAlt = high;

}

getRTC.ino

Arduino
// Real-Time Tlock
// Date and Time RTC
void isRTC () {

  // Date and Time
  dateRTC = "";
  timeRTC = "";
  rtc.read();
  
  // Date
  dateRTC = rtc.year; 
  dateRTC = dateRTC + "/";
  dateRTC = dateRTC + rtc.month;
  dateRTC = dateRTC + "/";
  dateRTC = dateRTC + rtc.day;

  // Time
  timeRTC = rtc.hour;
  timeRTC = timeRTC + ":";
  timeRTC = timeRTC + rtc.minute;
  timeRTC = timeRTC + ":";
  timeRTC = timeRTC + rtc.second;
  
}

setup.ino

Arduino
// Setup
void setup()
{
 
  // Delay
  delay( 100 );

  // isSetupGNSS
  isSetupGNSS();

  // Delay
  delay(100);

  // Setup RTC
  rtc.setup();

  //Set the RTC time automatically: Calibrate RTC time by your computer time
  rtc.adjustRtc(F(__DATE__), F(__TIME__));

  // Delay
  delay(100);

  // DFRobot Display 320x480
  screen.begin();

  // Delay
  delay( 100 );

  // DFRobot Display 320x480 - UID
  // Don Luc Electronics
  // Version
  isDisplayUID();

  // Wait for the sensor to heat up for 20 seconds
  delay( 5000 );

}

Credits

Luc Paquin
98 projects • 5 followers
Teacher, Instructor, E-Mentor, R&D and Consulting -Programming Language -Microcontrollers -IoT -Robotics -Machine Learning -AI -Sensors

Comments