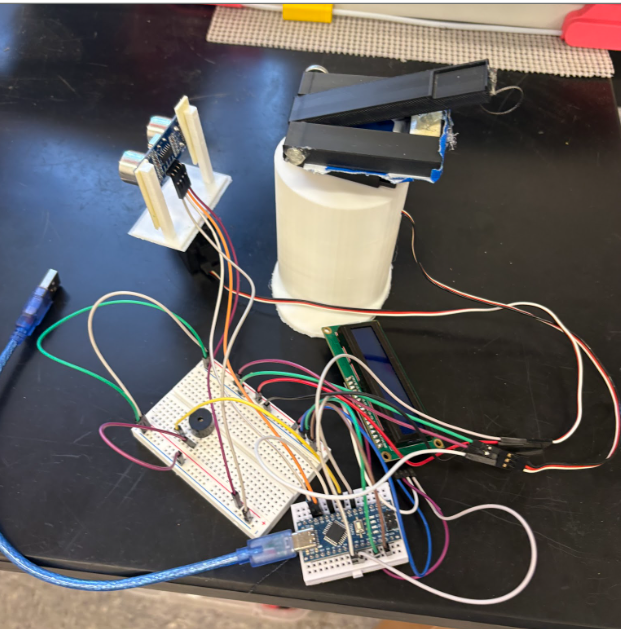
The project started with multiple ideas and different brainstorms. After weighing all my options I decided to try and build a pie launcher to begin with (whipped cream would have been thrown). My first challenge was the shape, I ended with a 3D printed tower to raise the servo, the one that held the launcher, higher than the Ultrasonic Range Finder. The tower was also shaped to work as a grip for better stability. For the Ultrasonic range finder, I build a small stand to have it attach to the servo on the ground. After I had put them all into TinkerCAD, I went to focus on the launcher. The launcher had many different designs. I originally planned for an auto wind-and-release launcher, however, I noticed that it was too complicated to design holding and trigger mechanisms so I shifted to a simpler design: the 3 legged catapult. The next challenge was to get a spring to bounce the middle leg. The original idea was to mess around with PLA's elasticity, then we shifted to TPU's elasticity. After both ideas failed, I figured I could modify a spring found in a pen by cutting the height, and it worked. The assembly was very short once all the parts were made. The tape is from minor design flaws, however the system works and is functional. After a few measurements of how far the catapult launched an average pill and the rope to stop the catapult, the final build was finished. The code came after and only a few minor complications came from it but in the end it all fit in to place and the final product was complete. The SONAR(Ultrasonic Range Finder) is to be placed 3 cm in front of the tower for best accuracy.




Comments