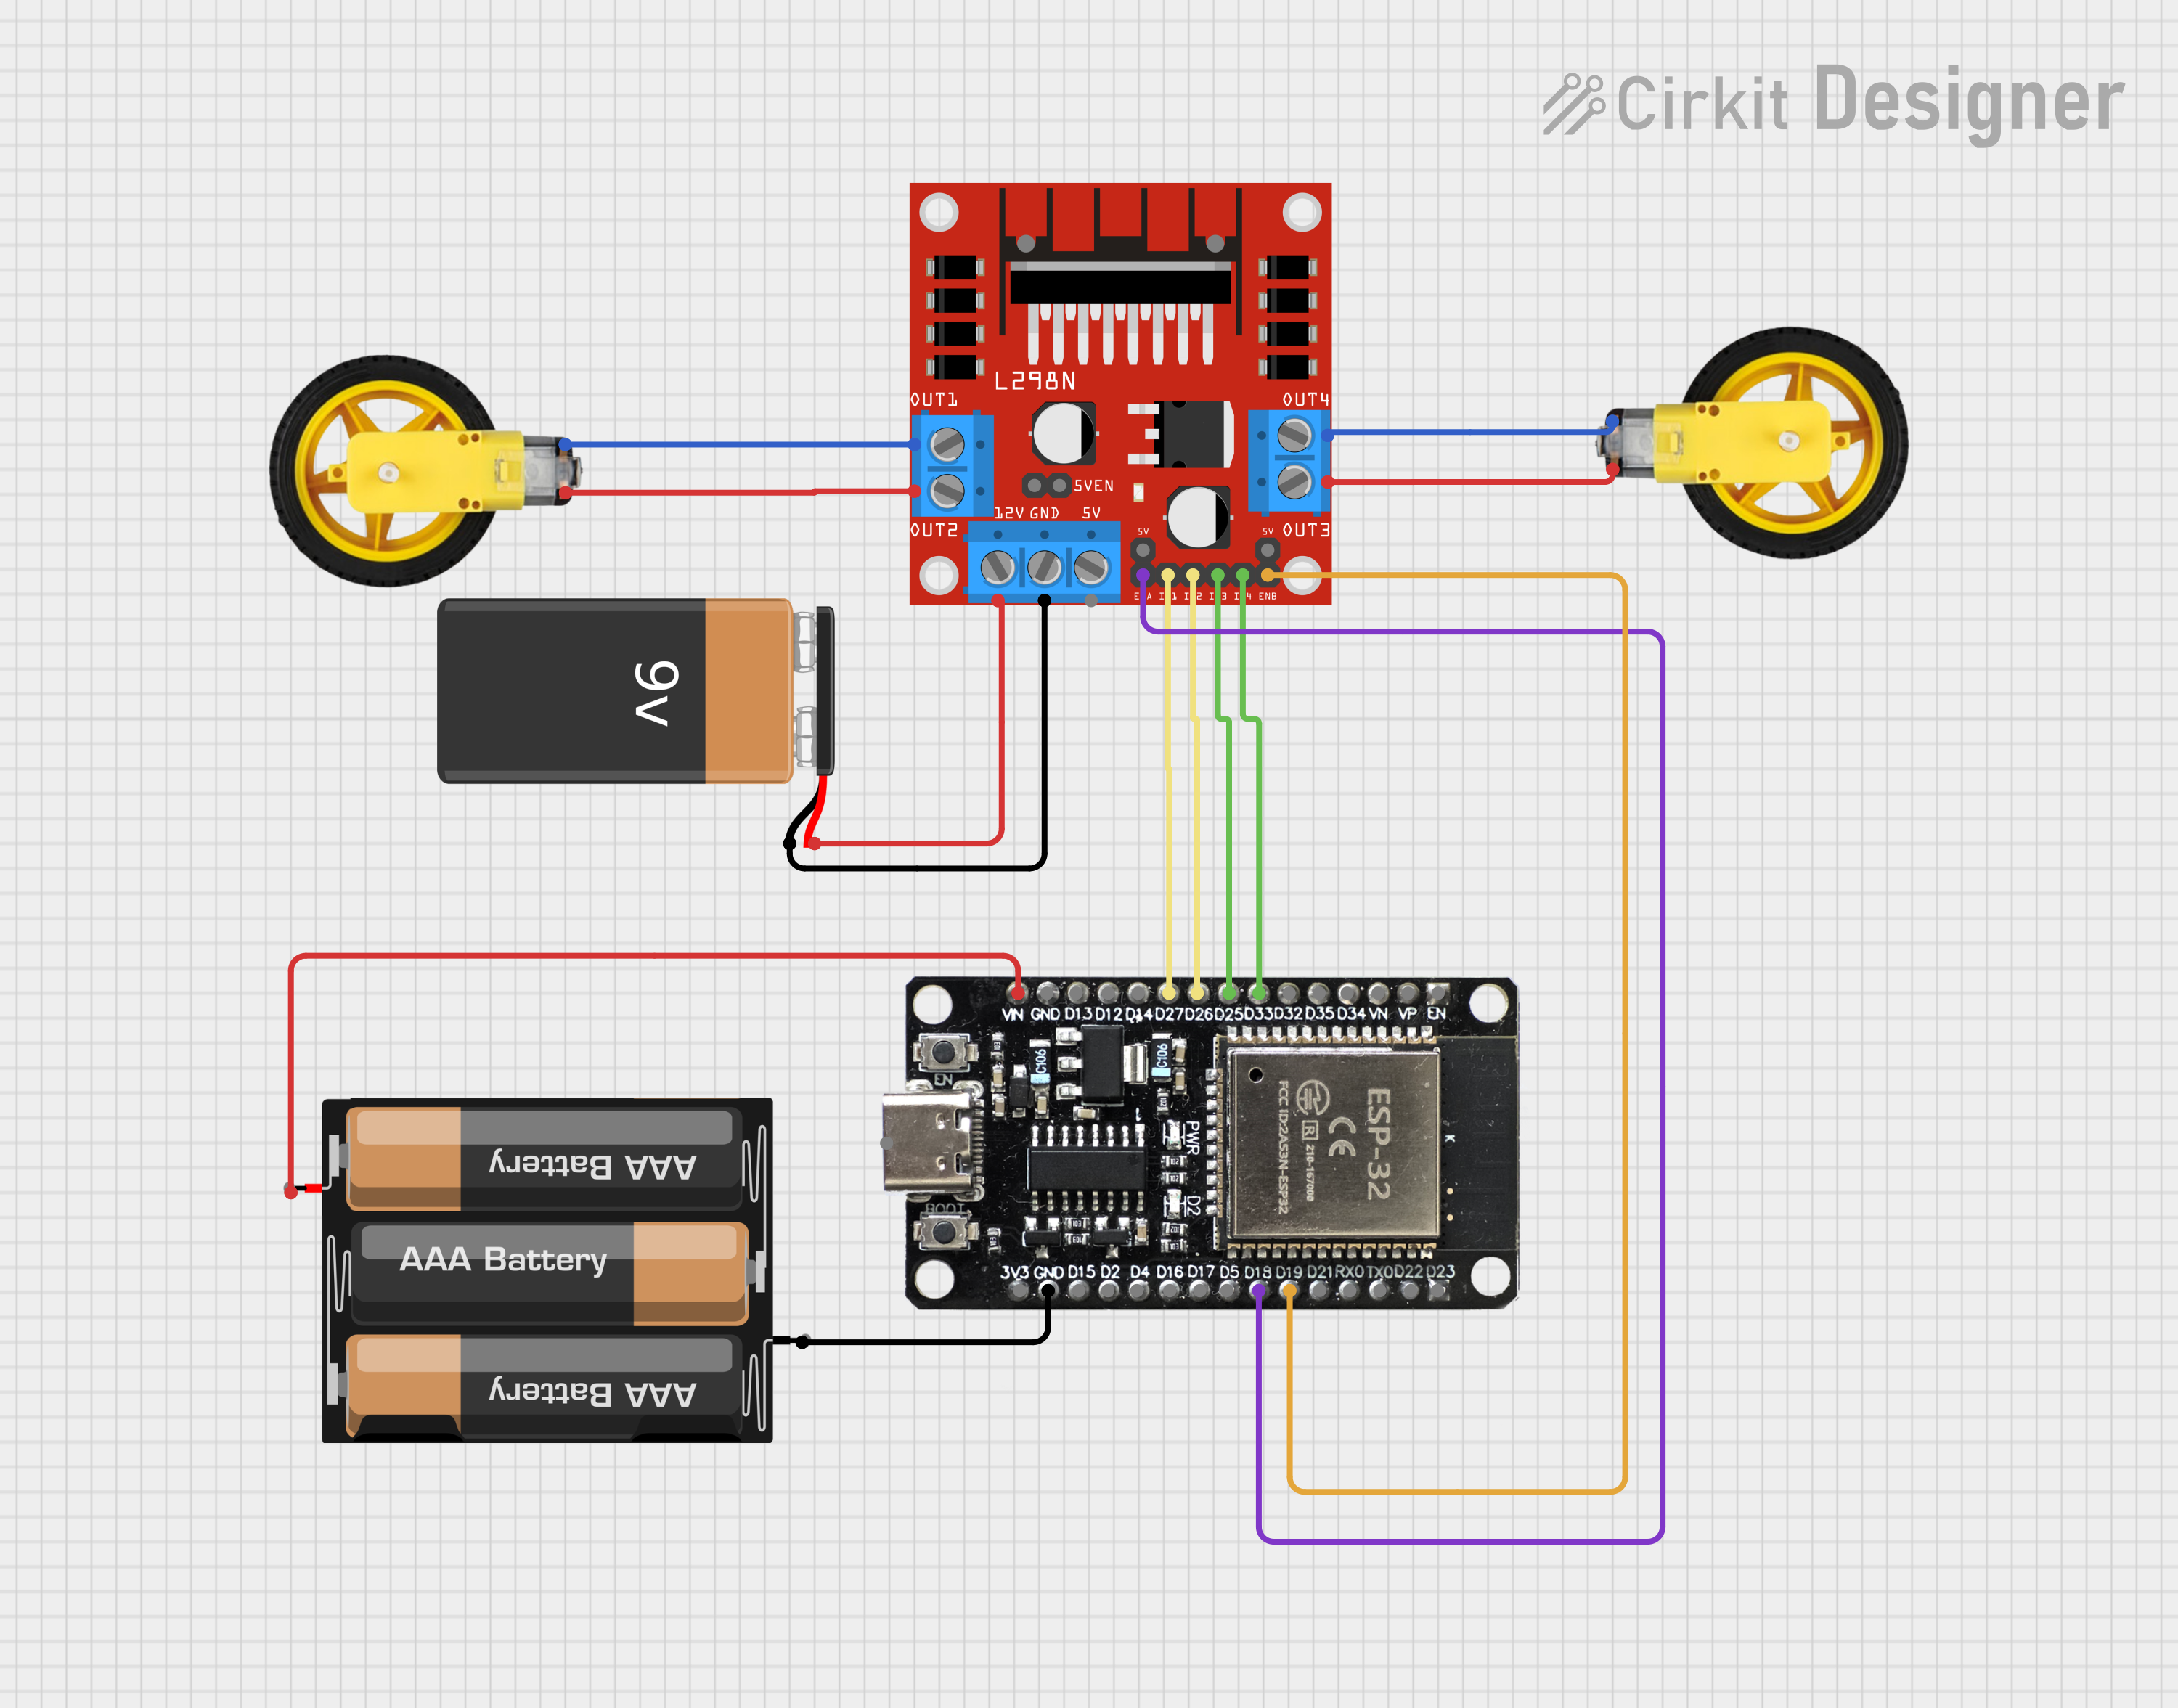
For this project, I built an Autonomous A* Path-finding robot. The goal is for the robot to traverse through a digital grid. In this digital grid there are also obstacles which are also present in the grid. The robot finds the quickest path from the start to the goal using the A* algorithm, which is done in Python. Once it has gotten the path, it then converts the path into a string of letters of either 'U' for Up, 'R' for Right, 'D' for Down, and 'L' for Left. These string of letters are then sent to the ESP32 one-by-one through wifi connection which tells the robot which direction to move. Below is a video showcase of this project.




Comments