



When training a dog, one of the common problems to resolve is the dog straining against the leash. This pulling is resolved with commands or training collars. However, these corrections are not instantaneous and dogs learn better when the correction is directly related, and in direct proportion, to the behaviour. Here is an example of my dog pulling during an initial experiment to determine how much pull she can exert.
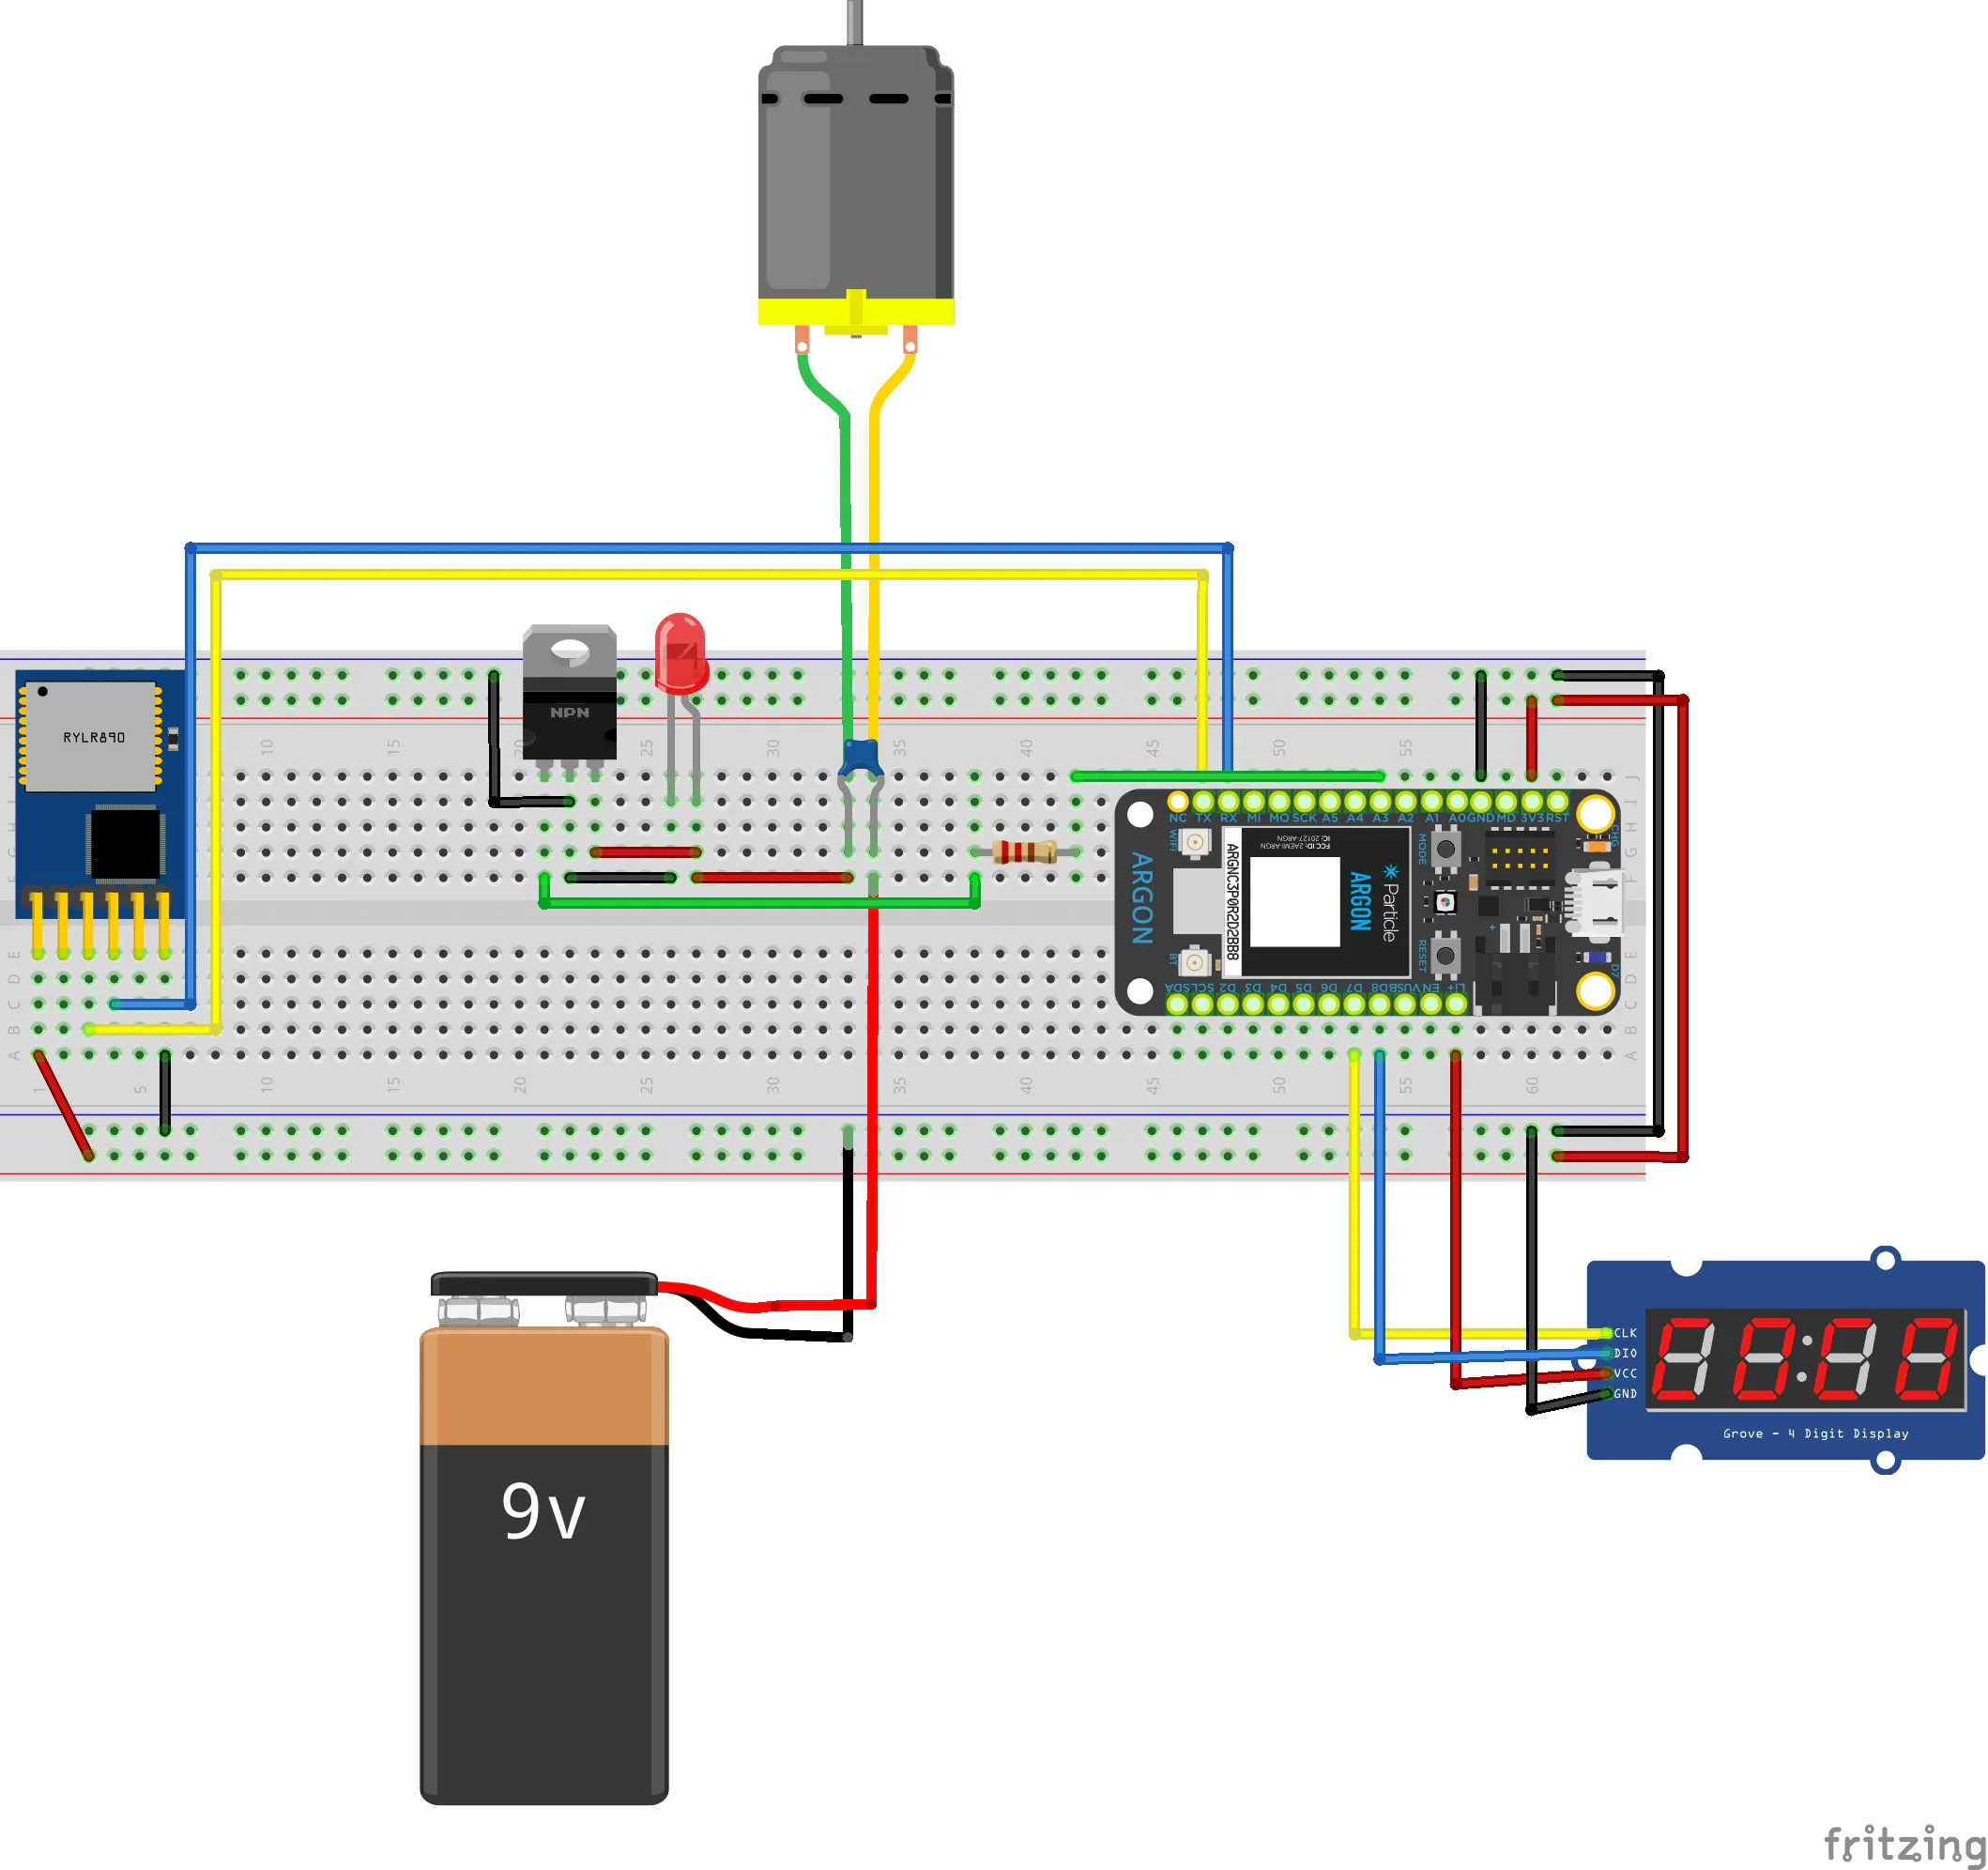
My solution is the Smart Leash. The current version has a transmitter and a load cell on the leash and a receiver and an off-center motor on the collar. As the dog strains on the leash, the load is sensed by the load cells. This valus is transmitted as a correction to the receiver which runs the vibratory motor at a speed directly proportional to the amount of strain on the leash. This is the desk run of the system.
At the same time, the transmitter is also publishing a maximum load number to a bluetooth-enables phone every ten seconds for analysis later.
The final version of this project will not have a collar component. I envision a transmitter/leash system that can interact with existing training collars and just send correction signals to those collars.


Comments