Overview
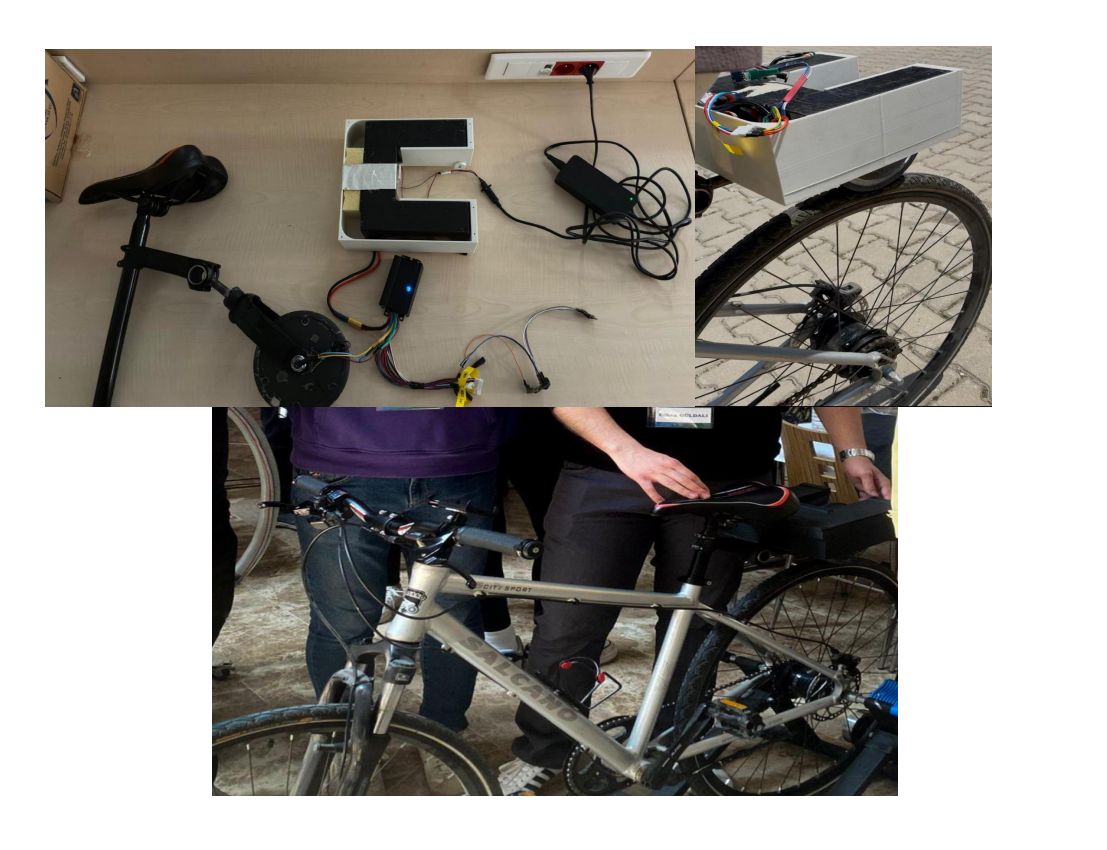
This project upgrades a standard e-bike conversion into an industrial-grade R&D testbed. It focuses on integrating hardware-in-the-loop (HIL) testing, closed-loop Field Oriented Control (FOC), and real-time IoT telemetry using an ESP32 micro-controller and a VESC motor driver.
System Architecture & Control
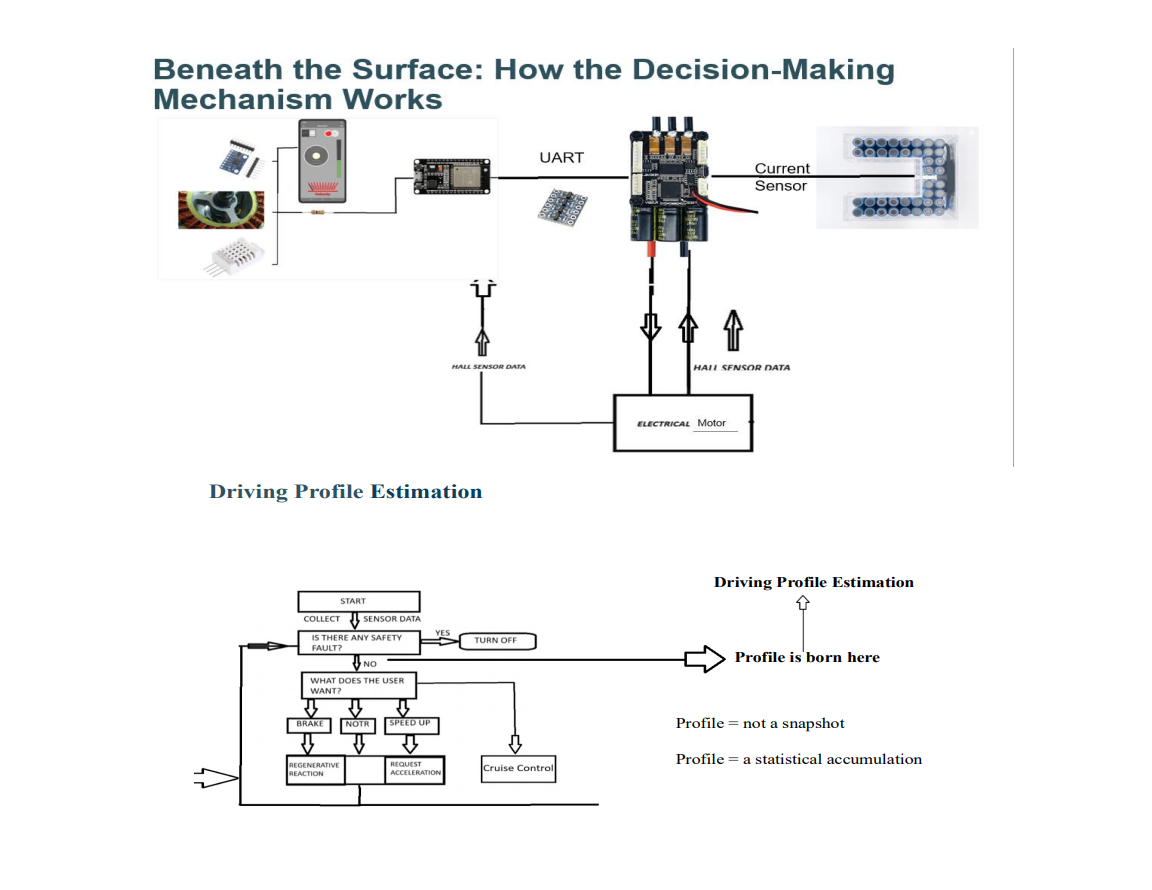
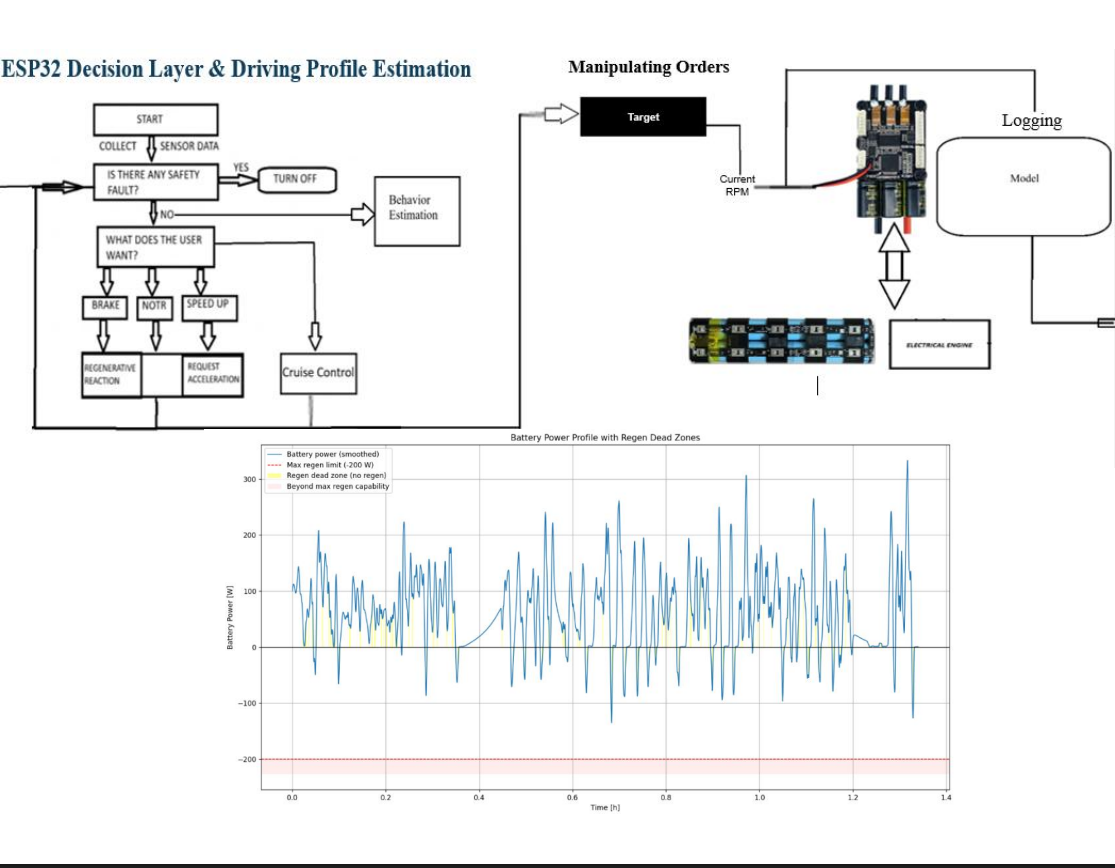
The core of the system relies on bi-directional UART communication between the ESP32 and VESC. Instead of simple PWM throttle inputs, the ESP32 calculates required traction, processes real-time kinematics based on a custom 141mm friction drive interface, and sends precise current/RPM commands to the VESC. Real-time telemetry (speed, current, fault codes) is streamed directly to a mobile dashboard via the RemoteXY IoT platform.
Mechanical Integration (DFM) & Vibration Damping
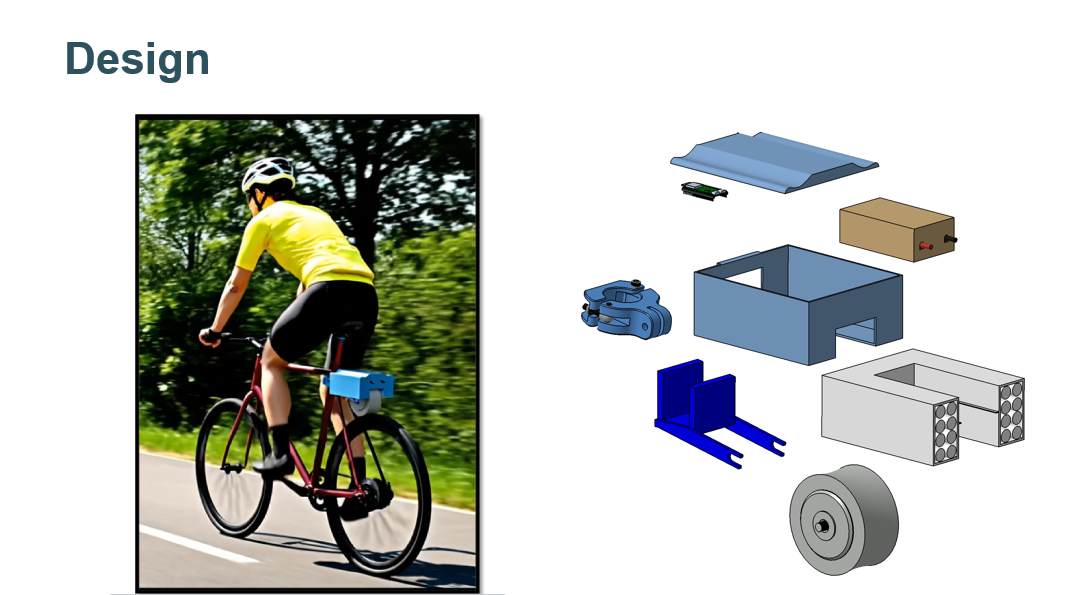
High-torque BLDC motors introduce severe high-frequency vibrations to the vehicle frame. By reverse-engineering the motor mounts in SolidWorks, I designed a custom enclosure featuring integrated polyamide dampers. This mechanical design approach significantly reduces mechanical fatigue and ensures stable sensor data acquisition during operation.




Comments