



Hardware components | ||||||
| × | 1 | ||||
| × | 1 | ||||
| × | 1 | ||||
Software apps and online services | ||||||
| ||||||
| ||||||
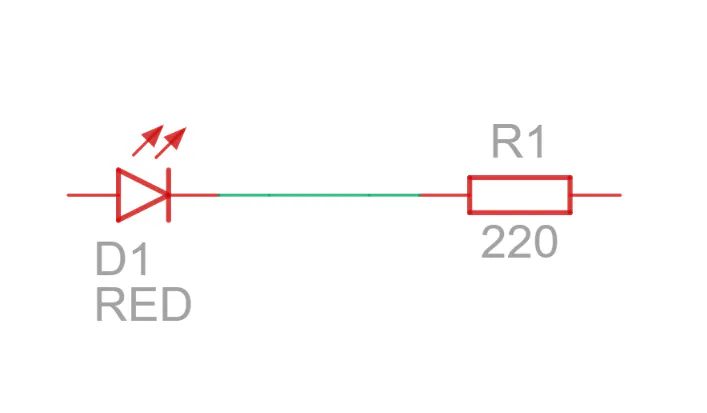
This assignment involves creating a simple digital clock using the RT-Thread RT-Spark Development Board, which is based on the STM32F407 microcontroller. The clock displays the current time on an LCD screen and blinks an LED every second. Instead of simply turning on and off, the LED gradually fades from bright to off using PWM (Pulse Width Modulation).
The main goal of the project is to demonstrate the use of timers and interrupts in embedded systems. A hardware timer keeps track of time in the background and signals the main program when tasks need to be performed, such as updating the LCD display or controlling the LED brightness.
Pinout & ConfigurationSystem Core
- GPIO
Figure 1: GPIO Configuration for LCD
Configuring GPIO pins PD3 and PF9 for LCD Reset and Backlight control.
TIMERS
- RTC
Figure 2: RTC Configuration
Configuring RTC with activated clock source, calendar enabled, and 24-hour format setting.
- TIM2
Figure 3. TIM2 Configuration
Configuring TIM2 with Internal Clock, PWM Generation on Channel 1, Prescaler set to 99, and Counter Period set to 159.
Figure 4. TIM2 NVIC Configuration
Enabling the TIM2 global interrupt in the NVIC Settings tab.
- TIM3
Figure 5: TIM3 Configuration
Configuring TIM3 with Internal Clock, Prescaler set to 15, and Counter Period set to 999.
Figure 6: TIM3 NVIC Configuration
Enabling the TIM3 global interrupt in the NVIC Settings tab.
Video Demonstration
/* USER CODE BEGIN Header */
/**
  ****************************************************************************
  * @file           : main.c
  * @brief          : Main program body
  ****************************************************************************
  * @attention
  *
  * Copyright (c) 2026 STMicroelectronics.
  * All rights reserved.
  *
  * This software is licensed under terms that can be found in the LICENSE file
  * in the root directory of this software component.
  * If no LICENSE file comes with this software, it is provided AS-IS.
  *
  ****************************************************************************
  */
/* USER CODE END Header */
/* Includes ------------------------------------------------------------------*/
#include "main.h"

/* Private includes ----------------------------------------------------------*/
/* USER CODE BEGIN Includes */
#include "drv_lcd.h"
#include "stdio.h"
/* USER CODE END Includes */

/* Private typedef -----------------------------------------------------------*/
/* USER CODE BEGIN PTD */

/* USER CODE END PTD */

/* Private define ------------------------------------------------------------*/
/* USER CODE BEGIN PD */

/* USER CODE END PD */

/* Private macro -------------------------------------------------------------*/
/* USER CODE BEGIN PM */

/* USER CODE END PM */

/* Private variables ---------------------------------------------------------*/
RTC_HandleTypeDef hrtc;

TIM_HandleTypeDef htim2;
TIM_HandleTypeDef htim3;

SRAM_HandleTypeDef hsram1;

/* USER CODE BEGIN PV */
volatile uint8_t updateled = 0;
volatile uint8_t lcd_update_requested = 0;

volatile uint16_t global_time = 0;

RTC_TimeTypeDef sTime = {0};
RTC_DateTypeDef sDate = {0};
/* USER CODE END PV */

/* Private function prototypes -----------------------------------------------*/
void SystemClock_Config(void);
static void MX_GPIO_Init(void);
static void MX_TIM2_Init(void);
static void MX_FSMC_Init(void);
static void MX_TIM3_Init(void);
static void MX_RTC_Init(void);
/* USER CODE BEGIN PFP */

/* USER CODE END PFP */

/* Private user code ---------------------------------------------------------*/
/* USER CODE BEGIN 0 */
void HAL_TIM_PeriodElapsedCallback(TIM_HandleTypeDef *htim) {
	if(htim->Instance == TIM2) {
		updateled = 1;
	}

	if(htim->Instance == TIM3) {
		global_time++;

		if(global_time >= 1000) {
			global_time = 0;
		}

		if(global_time % 100 == 0) {
			lcd_update_requested = 1;
		}
	}
}

void ledFade(uint16_t system_ms) {
    uint32_t duty_cycle = 0;

    // Use the absolute system time instead of a local counter
    if(system_ms <= 600) {
        duty_cycle = 159 - ((159 * (uint16_t)system_ms) / 600);
        __HAL_TIM_SET_COMPARE(&htim2, TIM_CHANNEL_1, duty_cycle);
    } else {
        // Explicitly keep the LED off from 601ms to 999ms
        __HAL_TIM_SET_COMPARE(&htim2, TIM_CHANNEL_1, 0);
    }


	}


void lcdUpdate() {
	HAL_RTC_GetTime(&hrtc, &sTime, RTC_FORMAT_BIN);
	HAL_RTC_GetDate(&hrtc, &sDate, RTC_FORMAT_BIN);

	char timeINlcd[20];

	sprintf(timeINlcd, "%02d:%02d:%02d:%03d", sTime.Hours, sTime.Minutes, sTime.Seconds, global_time);

    lcd_set_color(YELLOW, BLACK);       // <-- set font BLACK, background CYAN
	lcd_show_string(8, 100, 32, timeINlcd);
}
/* USER CODE END 0 */

/**
  * @brief  The application entry point.
  * @retval int
  */
int main(void)
{

  /* USER CODE BEGIN 1 */

  /* USER CODE END 1 */

  /* MCU Configuration--------------------------------------------------------*/

  /* Reset of all peripherals, Initializes the Flash interface and the Systick. */
  HAL_Init();

  /* USER CODE BEGIN Init */

  /* USER CODE END Init */

  /* Configure the system clock */
  SystemClock_Config();

  /* USER CODE BEGIN SysInit */

  /* USER CODE END SysInit */

  /* Initialize all configured peripherals */
  MX_GPIO_Init();
  MX_TIM2_Init();
  MX_FSMC_Init();
  MX_TIM3_Init();
  MX_RTC_Init();
  /* USER CODE BEGIN 2 */
  HAL_TIM_Base_Start_IT(&htim2);
  HAL_TIM_Base_Start_IT(&htim3);

  HAL_TIM_PWM_Start(&htim2, TIM_CHANNEL_1);

  drv_lcd_init();
  lcd_clear(YELLOW);
  /* USER CODE END 2 */

  /* Infinite loop */
  /* USER CODE BEGIN WHILE */
  while (1)
  {
    /* USER CODE END WHILE */

    /* USER CODE BEGIN 3 */
	  if(updateled == 1) {
		  updateled = 0;
		  ledFade(global_time);
	  }

	  if(lcd_update_requested == 1) {
		  lcd_update_requested = 0;
		  lcdUpdate();
	  }

  }
  /* USER CODE END 3 */
}

/**
  * @brief System Clock Configuration
  * @retval None
  */
void SystemClock_Config(void)
{
  RCC_OscInitTypeDef RCC_OscInitStruct = {0};
  RCC_ClkInitTypeDef RCC_ClkInitStruct = {0};

  /** Configure the main internal regulator output voltage
  */
  __HAL_RCC_PWR_CLK_ENABLE();
  __HAL_PWR_VOLTAGESCALING_CONFIG(PWR_REGULATOR_VOLTAGE_SCALE1);

  /** Initializes the RCC Oscillators according to the specified parameters
  * in the RCC_OscInitTypeDef structure.
  */
  RCC_OscInitStruct.OscillatorType = RCC_OSCILLATORTYPE_HSI|RCC_OSCILLATORTYPE_LSI;
  RCC_OscInitStruct.HSIState = RCC_HSI_ON;
  RCC_OscInitStruct.HSICalibrationValue = RCC_HSICALIBRATION_DEFAULT;
  RCC_OscInitStruct.LSIState = RCC_LSI_ON;
  RCC_OscInitStruct.PLL.PLLState = RCC_PLL_NONE;
  if (HAL_RCC_OscConfig(&RCC_OscInitStruct) != HAL_OK)
  {
    Error_Handler();
  }

  /** Initializes the CPU, AHB and APB buses clocks
  */
  RCC_ClkInitStruct.ClockType = RCC_CLOCKTYPE_HCLK|RCC_CLOCKTYPE_SYSCLK
                              |RCC_CLOCKTYPE_PCLK1|RCC_CLOCKTYPE_PCLK2;
  RCC_ClkInitStruct.SYSCLKSource = RCC_SYSCLKSOURCE_HSI;
  RCC_ClkInitStruct.AHBCLKDivider = RCC_SYSCLK_DIV1;
  RCC_ClkInitStruct.APB1CLKDivider = RCC_HCLK_DIV1;
  RCC_ClkInitStruct.APB2CLKDivider = RCC_HCLK_DIV1;

  if (HAL_RCC_ClockConfig(&RCC_ClkInitStruct, FLASH_LATENCY_0) != HAL_OK)
  {
    Error_Handler();
  }
}

/**
  * @brief RTC Initialization Function
  * @param None
  * @retval None
  */
static void MX_RTC_Init(void)
{

  /* USER CODE BEGIN RTC_Init 0 */

  /* USER CODE END RTC_Init 0 */

  RTC_TimeTypeDef sTime = {0};
  RTC_DateTypeDef sDate = {0};

  /* USER CODE BEGIN RTC_Init 1 */

  /* USER CODE END RTC_Init 1 */

  /** Initialize RTC Only
  */
  hrtc.Instance = RTC;
  hrtc.Init.HourFormat = RTC_HOURFORMAT_24;
  hrtc.Init.AsynchPrediv = 127;
  hrtc.Init.SynchPrediv = 255;
  hrtc.Init.OutPut = RTC_OUTPUT_DISABLE;
  hrtc.Init.OutPutPolarity = RTC_OUTPUT_POLARITY_HIGH;
  hrtc.Init.OutPutType = RTC_OUTPUT_TYPE_OPENDRAIN;
  if (HAL_RTC_Init(&hrtc) != HAL_OK)
  {
    Error_Handler();
  }

  /* USER CODE BEGIN Check_RTC_BKUP */

  /* USER CODE END Check_RTC_BKUP */

  /** Initialize RTC and set the Time and Date
  */
  sTime.Hours = 0x0;
  sTime.Minutes = 0x0;
  sTime.Seconds = 0x0;
  sTime.DayLightSaving = RTC_DAYLIGHTSAVING_NONE;
  sTime.StoreOperation = RTC_STOREOPERATION_RESET;
  if (HAL_RTC_SetTime(&hrtc, &sTime, RTC_FORMAT_BCD) != HAL_OK)
  {
    Error_Handler();
  }
  sDate.WeekDay = RTC_WEEKDAY_FRIDAY;
  sDate.Month = RTC_MONTH_JUNE;
  sDate.Date = 0x5;
  sDate.Year = 0x26;

  if (HAL_RTC_SetDate(&hrtc, &sDate, RTC_FORMAT_BCD) != HAL_OK)
  {
    Error_Handler();
  }
  /* USER CODE BEGIN RTC_Init 2 */

  /* USER CODE END RTC_Init 2 */

}

/**
  * @brief TIM2 Initialization Function
  * @param None
  * @retval None
  */
static void MX_TIM2_Init(void)
{

  /* USER CODE BEGIN TIM2_Init 0 */

  /* USER CODE END TIM2_Init 0 */

  TIM_ClockConfigTypeDef sClockSourceConfig = {0};
  TIM_MasterConfigTypeDef sMasterConfig = {0};
  TIM_OC_InitTypeDef sConfigOC = {0};

  /* USER CODE BEGIN TIM2_Init 1 */

  /* USER CODE END TIM2_Init 1 */
  htim2.Instance = TIM2;
  htim2.Init.Prescaler = 99;
  htim2.Init.CounterMode = TIM_COUNTERMODE_UP;
  htim2.Init.Period = 159;
  htim2.Init.ClockDivision = TIM_CLOCKDIVISION_DIV1;
  htim2.Init.AutoReloadPreload = TIM_AUTORELOAD_PRELOAD_DISABLE;
  if (HAL_TIM_Base_Init(&htim2) != HAL_OK)
  {
    Error_Handler();
  }
  sClockSourceConfig.ClockSource = TIM_CLOCKSOURCE_INTERNAL;
  if (HAL_TIM_ConfigClockSource(&htim2, &sClockSourceConfig) != HAL_OK)
  {
    Error_Handler();
  }
  if (HAL_TIM_PWM_Init(&htim2) != HAL_OK)
  {
    Error_Handler();
  }
  sMasterConfig.MasterOutputTrigger = TIM_TRGO_RESET;
  sMasterConfig.MasterSlaveMode = TIM_MASTERSLAVEMODE_DISABLE;
  if (HAL_TIMEx_MasterConfigSynchronization(&htim2, &sMasterConfig) != HAL_OK)
  {
    Error_Handler();
  }
  sConfigOC.OCMode = TIM_OCMODE_PWM1;
  sConfigOC.Pulse = 0;
  sConfigOC.OCPolarity = TIM_OCPOLARITY_HIGH;
  sConfigOC.OCFastMode = TIM_OCFAST_DISABLE;
  if (HAL_TIM_PWM_ConfigChannel(&htim2, &sConfigOC, TIM_CHANNEL_1) != HAL_OK)
  {
    Error_Handler();
  }
  /* USER CODE BEGIN TIM2_Init 2 */

  /* USER CODE END TIM2_Init 2 */
  HAL_TIM_MspPostInit(&htim2);

}

/**
  * @brief TIM3 Initialization Function
  * @param None
  * @retval None
  */
static void MX_TIM3_Init(void)
{

  /* USER CODE BEGIN TIM3_Init 0 */

  /* USER CODE END TIM3_Init 0 */

  TIM_ClockConfigTypeDef sClockSourceConfig = {0};
  TIM_MasterConfigTypeDef sMasterConfig = {0};

  /* USER CODE BEGIN TIM3_Init 1 */

  /* USER CODE END TIM3_Init 1 */
  htim3.Instance = TIM3;
  htim3.Init.Prescaler = 15;
  htim3.Init.CounterMode = TIM_COUNTERMODE_UP;
  htim3.Init.Period = 999;
  htim3.Init.ClockDivision = TIM_CLOCKDIVISION_DIV1;
  htim3.Init.AutoReloadPreload = TIM_AUTORELOAD_PRELOAD_DISABLE;
  if (HAL_TIM_Base_Init(&htim3) != HAL_OK)
  {
    Error_Handler();
  }
  sClockSourceConfig.ClockSource = TIM_CLOCKSOURCE_INTERNAL;
  if (HAL_TIM_ConfigClockSource(&htim3, &sClockSourceConfig) != HAL_OK)
  {
    Error_Handler();
  }
  sMasterConfig.MasterOutputTrigger = TIM_TRGO_RESET;
  sMasterConfig.MasterSlaveMode = TIM_MASTERSLAVEMODE_DISABLE;
  if (HAL_TIMEx_MasterConfigSynchronization(&htim3, &sMasterConfig) != HAL_OK)
  {
    Error_Handler();
  }
  /* USER CODE BEGIN TIM3_Init 2 */

  /* USER CODE END TIM3_Init 2 */

}

/**
  * @brief GPIO Initialization Function
  * @param None
  * @retval None
  */
static void MX_GPIO_Init(void)
{
  GPIO_InitTypeDef GPIO_InitStruct = {0};
  /* USER CODE BEGIN MX_GPIO_Init_1 */

  /* USER CODE END MX_GPIO_Init_1 */

  /* GPIO Ports Clock Enable */
  __HAL_RCC_GPIOF_CLK_ENABLE();
  __HAL_RCC_GPIOA_CLK_ENABLE();
  __HAL_RCC_GPIOE_CLK_ENABLE();
  __HAL_RCC_GPIOD_CLK_ENABLE();
  __HAL_RCC_GPIOG_CLK_ENABLE();

  /*Configure GPIO pin Output Level */
  HAL_GPIO_WritePin(BACKLIGHT_LCD_GPIO_Port, BACKLIGHT_LCD_Pin, GPIO_PIN_RESET);

  /*Configure GPIO pin Output Level */
  HAL_GPIO_WritePin(RESET_LCD_GPIO_Port, RESET_LCD_Pin, GPIO_PIN_RESET);

  /*Configure GPIO pin : BACKLIGHT_LCD_Pin */
  GPIO_InitStruct.Pin = BACKLIGHT_LCD_Pin;
  GPIO_InitStruct.Mode = GPIO_MODE_OUTPUT_PP;
  GPIO_InitStruct.Pull = GPIO_NOPULL;
  GPIO_InitStruct.Speed = GPIO_SPEED_FREQ_LOW;
  HAL_GPIO_Init(BACKLIGHT_LCD_GPIO_Port, &GPIO_InitStruct);

  /*Configure GPIO pin : RESET_LCD_Pin */
  GPIO_InitStruct.Pin = RESET_LCD_Pin;
  GPIO_InitStruct.Mode = GPIO_MODE_OUTPUT_PP;
  GPIO_InitStruct.Pull = GPIO_NOPULL;
  GPIO_InitStruct.Speed = GPIO_SPEED_FREQ_LOW;
  HAL_GPIO_Init(RESET_LCD_GPIO_Port, &GPIO_InitStruct);

  /* USER CODE BEGIN MX_GPIO_Init_2 */

  /* USER CODE END MX_GPIO_Init_2 */
}

/* FSMC initialization function */
static void MX_FSMC_Init(void)
{

  /* USER CODE BEGIN FSMC_Init 0 */

  /* USER CODE END FSMC_Init 0 */

  FSMC_NORSRAM_TimingTypeDef Timing = {0};

  /* USER CODE BEGIN FSMC_Init 1 */

  /* USER CODE END FSMC_Init 1 */

  /** Perform the SRAM1 memory initialization sequence
  */
  hsram1.Instance = FSMC_NORSRAM_DEVICE;
  hsram1.Extended = FSMC_NORSRAM_EXTENDED_DEVICE;
  /* hsram1.Init */
  hsram1.Init.NSBank = FSMC_NORSRAM_BANK3;
  hsram1.Init.DataAddressMux = FSMC_DATA_ADDRESS_MUX_DISABLE;
  hsram1.Init.MemoryType = FSMC_MEMORY_TYPE_SRAM;
  hsram1.Init.MemoryDataWidth = FSMC_NORSRAM_MEM_BUS_WIDTH_8;
  hsram1.Init.BurstAccessMode = FSMC_BURST_ACCESS_MODE_DISABLE;
  hsram1.Init.WaitSignalPolarity = FSMC_WAIT_SIGNAL_POLARITY_LOW;
  hsram1.Init.WrapMode = FSMC_WRAP_MODE_DISABLE;
  hsram1.Init.WaitSignalActive = FSMC_WAIT_TIMING_BEFORE_WS;
  hsram1.Init.WriteOperation = FSMC_WRITE_OPERATION_ENABLE;
  hsram1.Init.WaitSignal = FSMC_WAIT_SIGNAL_DISABLE;
  hsram1.Init.ExtendedMode = FSMC_EXTENDED_MODE_DISABLE;
  hsram1.Init.AsynchronousWait = FSMC_ASYNCHRONOUS_WAIT_DISABLE;
  hsram1.Init.WriteBurst = FSMC_WRITE_BURST_DISABLE;
  hsram1.Init.PageSize = FSMC_PAGE_SIZE_NONE;
  /* Timing */
  Timing.AddressSetupTime = 1;
  Timing.AddressHoldTime = 15;
  Timing.DataSetupTime = 60;
  Timing.BusTurnAroundDuration = 0;
  Timing.CLKDivision = 16;
  Timing.DataLatency = 17;
  Timing.AccessMode = FSMC_ACCESS_MODE_A;
  /* ExtTiming */

  if (HAL_SRAM_Init(&hsram1, &Timing, NULL) != HAL_OK)
  {
    Error_Handler( );
  }

  /* USER CODE BEGIN FSMC_Init 2 */

  /* USER CODE END FSMC_Init 2 */
}

/* USER CODE BEGIN 4 */

/* USER CODE END 4 */

/**
  * @brief  This function is executed in case of error occurrence.
  * @retval None
  */
void Error_Handler(void)
{
  /* USER CODE BEGIN Error_Handler_Debug */
  /* User can add his own implementation to report the HAL error return state */
  __disable_irq();
  while (1)
  {
  }
  /* USER CODE END Error_Handler_Debug */
}
#ifdef USE_FULL_ASSERT
/**
  * @brief  Reports the name of the source file and the source line number
  *         where the assert_param error has occurred.
  * @param  file: pointer to the source file name
  * @param  line: assert_param error line source number
  * @retval None
  */
void assert_failed(uint8_t *file, uint32_t line)
{
  /* USER CODE BEGIN 6 */
  /* User can add his own implementation to report the file name and line number,
     ex: printf("Wrong parameters value: file %s on line %d\r\n", file, line) */
  /* USER CODE END 6 */
}
#endif /* USE_FULL_ASSERT */


Comments